仿真与训练Simulation & training
Isaac Sim / Isaac Lab / MuJoCo,配合 LeRobot 开展仿真验证、数据采集与模型训练。Use Isaac Sim, Isaac Lab and MuJoCo alongside LeRobot for simulation, data collection and model training.
VLAI ROBOTICS · K SERIES
全新 K1INTRODUCING K1
全向移动精细操作机器人
Omnidirectional Precision Robot
精细操作,全向移动。
Precision manipulation. Omnidirectional mobility.
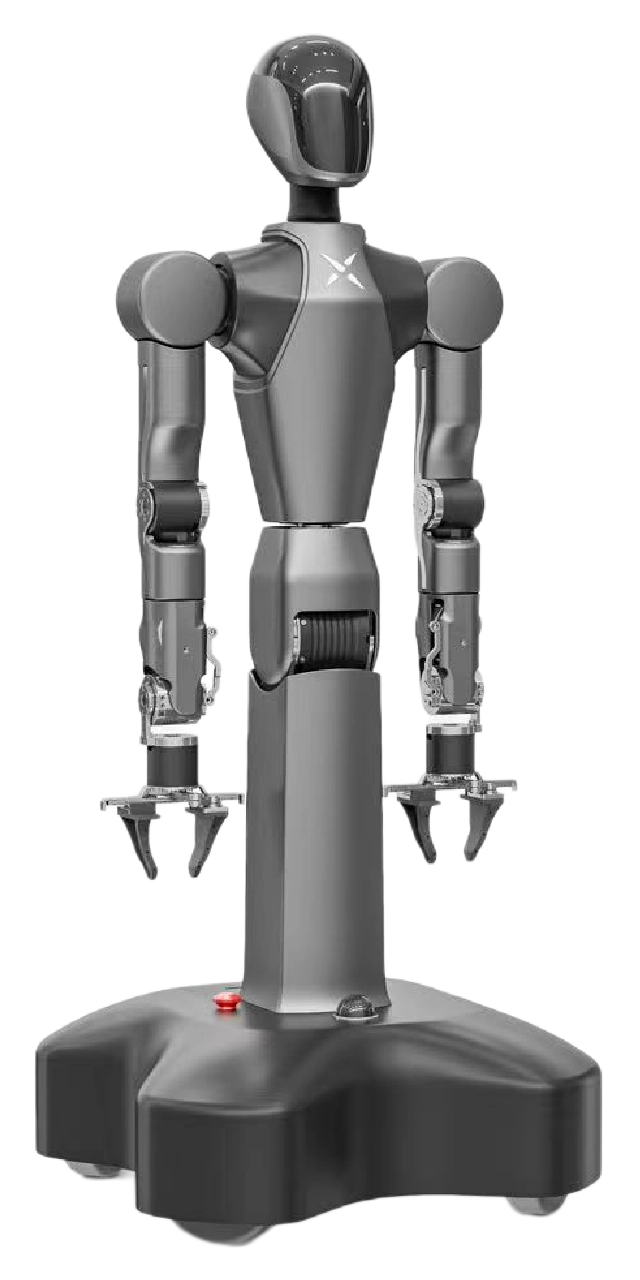
全向移动 · 精细操作Mobility · Precision
K1 IN ACTION
观看移动、取放与双臂操作的场景演示。Watch K1 demonstrate mobility, object handling and dual-arm operation.
PRODUCT OVERVIEW
围绕移动、升降与双臂操作,构建具身智能研发和应用集成平台。
A platform for embodied AI research and integration, combining mobility, lift and dual-arm manipulation.
放大查看 View larger SPECIFICATIONS
以下参数摘自 K1 产品手册,负载、底盘与开发功能因版本而异。Specifications from the K1 brochure. Payload, chassis and development features vary by edition.
最高单臂负载Maximum payload per arm
重复定位精度Repeatability
控制延迟Control latency
臂长Arm length
6 kg 单臂负载对应开发版及以上;全向移动对应开发版 Pro 及以上。机身与运动参数以所选配置为准。The 6 kg per-arm payload applies to Developer editions; omnidirectional mobility starts with Developer Pro. Body and motion specifications depend on the selected configuration.
可左右滑动查看完整配置Scroll horizontally to compare all editions
| 配置项目Configuration | 开发版Developer | 开发版 ProDeveloper Pro | 开发版 MaxDeveloper Max | 开发版 UltraDeveloper Ultra |
|---|---|---|---|---|
| 单臂 / 双臂负载Payload: per arm / both arms | 6 kg / 12 kg | 6 kg / 12 kg | 6 kg / 12 kg | 6 kg / 12 kg |
| 移动底盘Mobile base | 两驱差速Two-wheel differential | 四驱全向Four-wheel omnidirectional | 四驱全向Four-wheel omnidirectional | 四驱全向Four-wheel omnidirectional |
| 自动升降Automatic lift | 支持Supported | 支持Supported | 支持Supported | 支持Supported |
| 主控配置Controller | V2 · 10 TOPS | V3 · 67 TOPS | V5 · 117 TOPS | V6 · 256 TOPS |
| ROS 2 / MoveIt 2 / SDKROS 2 / MoveIt 2 / SDK | 支持Supported | 支持Supported | 支持Supported | 支持Supported |
| 仿真环境Simulation | Isaac Sim / Isaac Lab / MuJoCo | Isaac Sim / Isaac Lab / MuJoCo | Isaac Sim / Isaac Lab / MuJoCo | Isaac Sim / Isaac Lab / MuJoCo |
| 头部双目感知 / VR 遥操作功能Head stereo vision / VR teleoperation | 不支持Not supported | 支持Supported | 支持Supported | 支持Supported |
| 底盘激光雷达Chassis LiDAR | 不支持Not supported | 支持Supported | 支持Supported | 支持Supported |
| Quest 或 PICO 遥操作设备Quest or PICO teleoperation device | 不支持Not supported | 不支持Not supported | 支持Supported | 支持Supported |
| 腕部双摄 / VLA 例程Wrist cameras / VLA examples | 不支持Not supported | 不支持Not supported | 支持Supported | 支持Supported |
| 二次开发Secondary development | 支持Supported | 支持Supported | 支持Supported | 支持Supported |
DEVELOPMENT
开发版及以上提供二次开发支持,围绕具体任务开展集成。Developer editions support secondary development and task-specific integration.
Isaac Sim / Isaac Lab / MuJoCo,配合 LeRobot 开展仿真验证、数据采集与模型训练。Use Isaac Sim, Isaac Lab and MuJoCo alongside LeRobot for simulation, data collection and model training.
通过 CAN 2.0 / CAN-FD、ROS 2 与 MoveIt 2 对接机器人控制与应用系统。Integrate robot control and applications through CAN 2.0 / CAN-FD, ROS 2 and MoveIt 2.
支持主从遥操作、仿真示教与 VR 遥操作,具体功能和设备随版本配置。Master-slave operation, simulation teaching and VR teleoperation, with features and equipment depending on edition.
PRODUCT BROCHURE
产品规格、版本配置、开发方式与应用场景。完整手册同时收录 K1 与 K1-S 资料。Specifications, editions, development and applications. The complete brochure includes K1 and K1-S materials.
EXPLORE K1
联系未来动力团队,了解产品配置、开发支持与交付安排。
Contact the VLAI Robotics team for configurations, development support and delivery.